Published
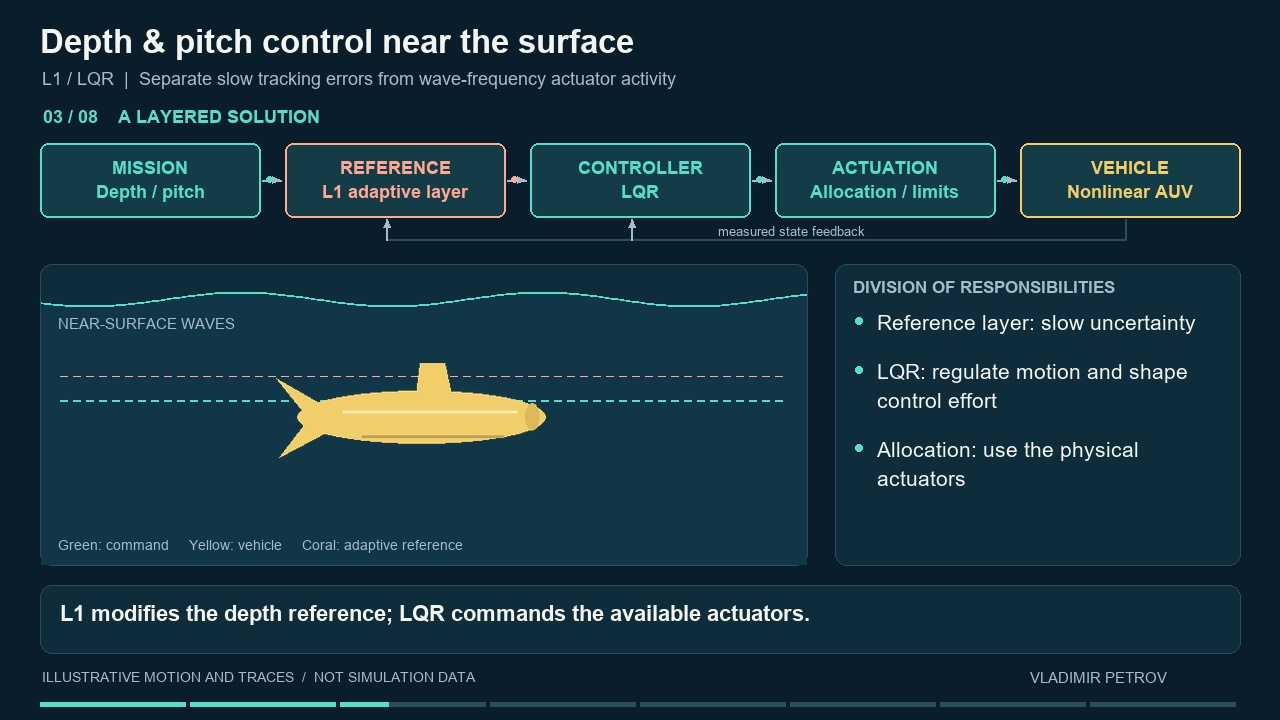
Depth & pitch control near the surface
Track a commanded depth while reducing unnecessary actuator activity in waves.
University of Iowa · 2023–present
Underwater control, aerial planning and learning for robots in changing environments.
Track a commanded depth while reducing unnecessary actuator activity in waves.
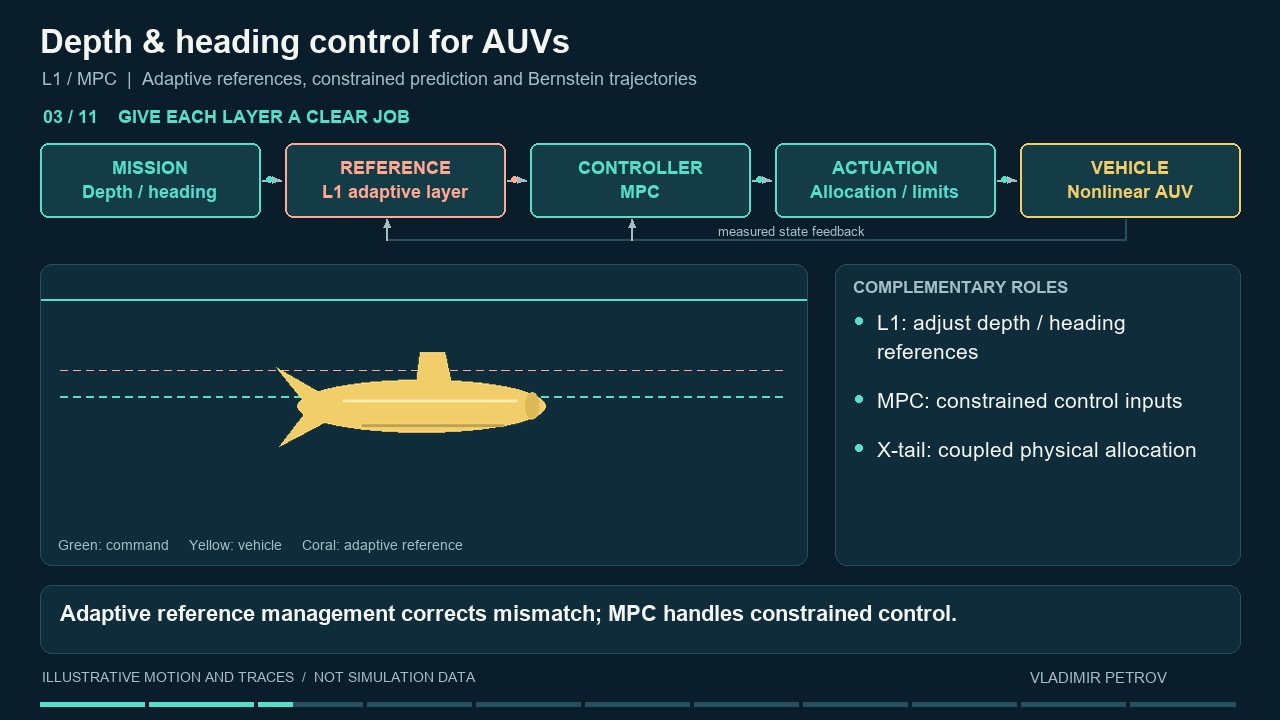
Reach a new depth and heading while working within the vehicle’s actuator limits.
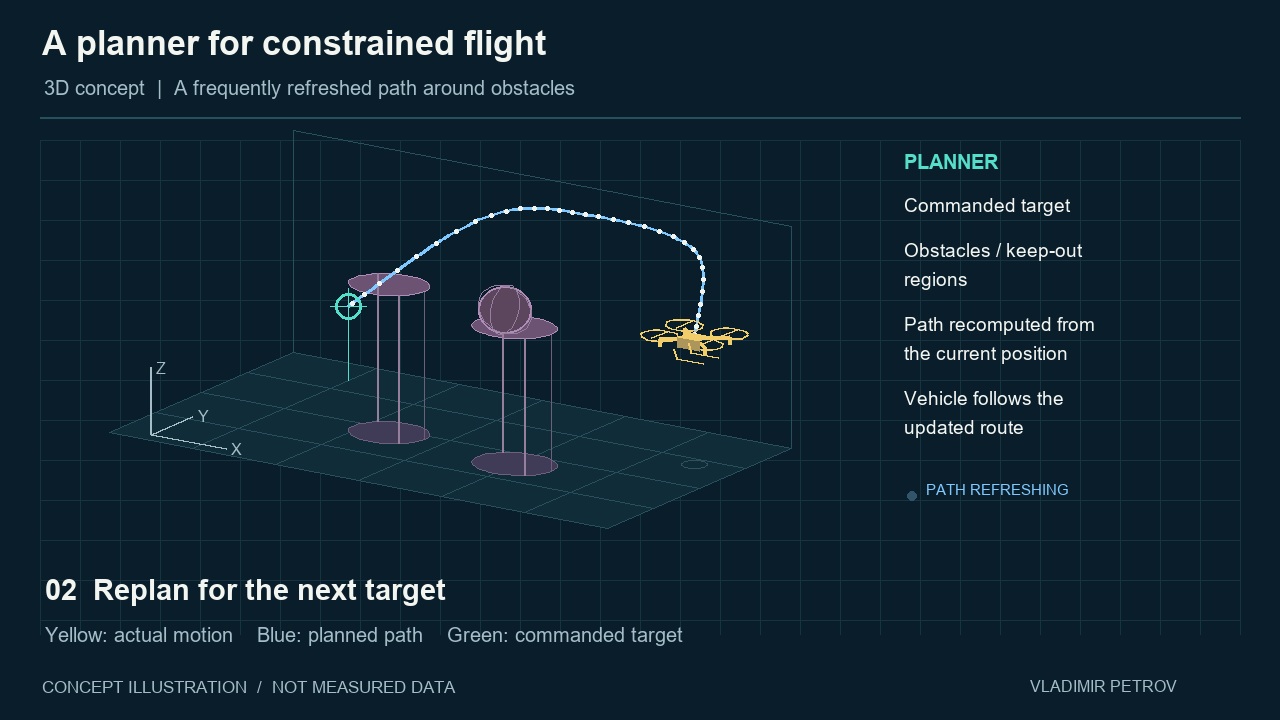
Guide a small drone toward a commanded target through a space with obstacles.
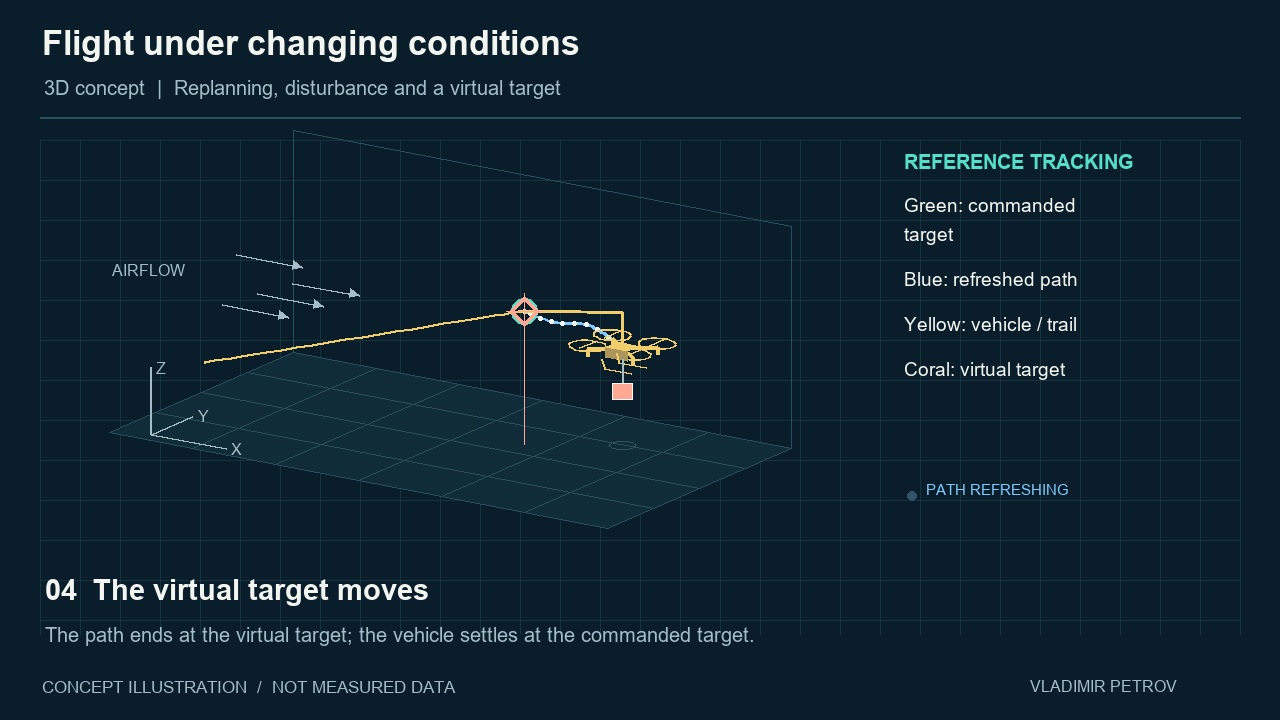
Return to a commanded position despite airflow and changes in carried mass.
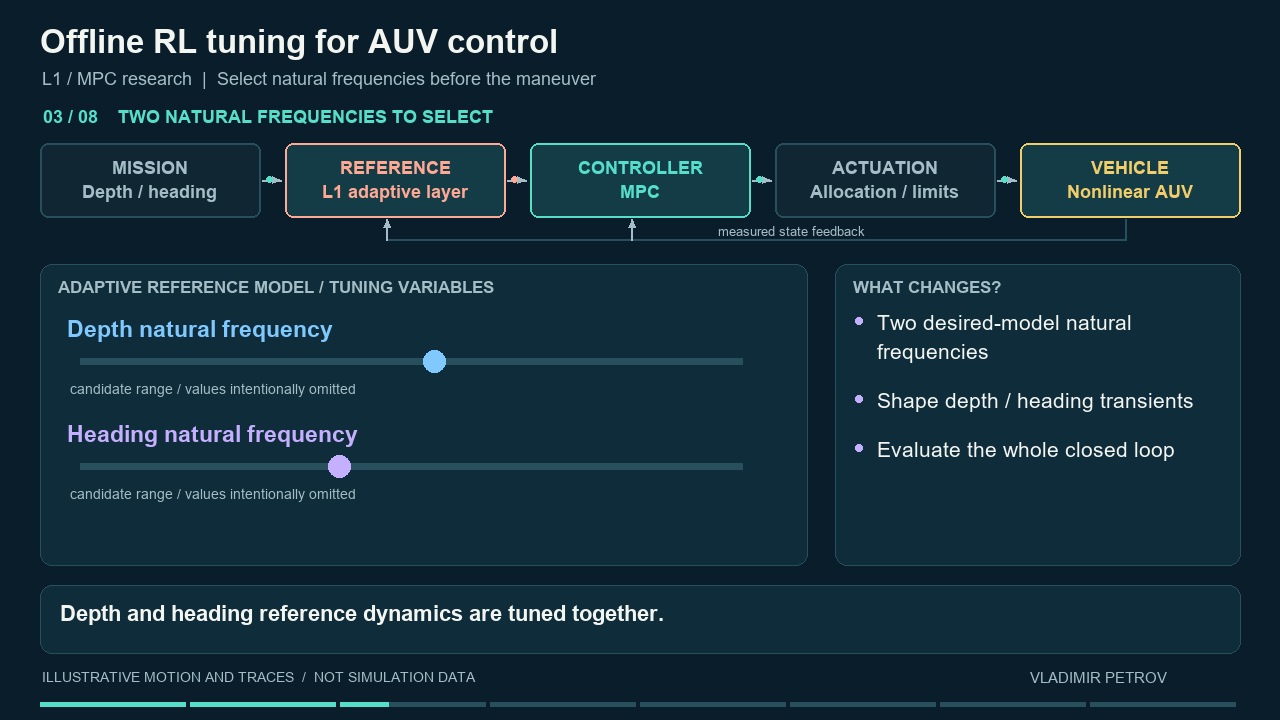
Use offline reinforcement learning to select controller settings for depth and heading maneuvers.
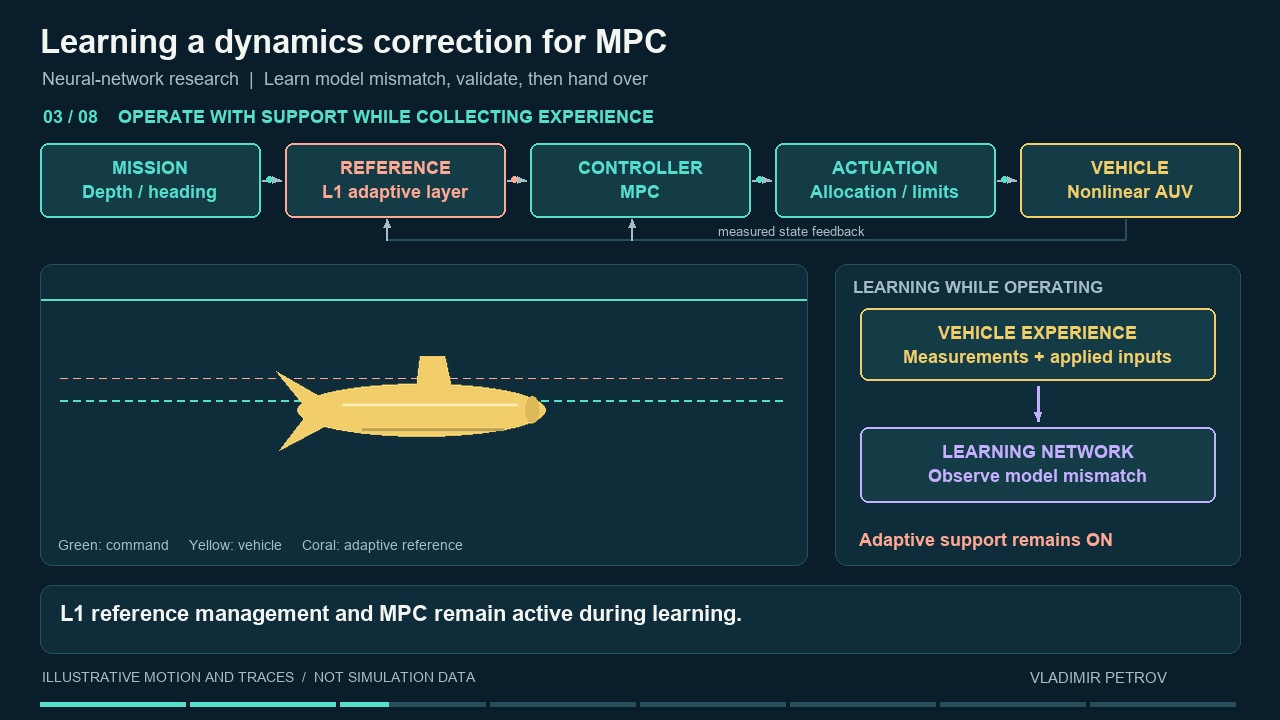
Learn a reusable model correction and investigate a validated handover from adaptive support to learned predictive control.