Published
Depth & pitch control near the surface
Track a commanded depth while reducing unnecessary actuator activity in waves.
Selected engineering & research
I work on control, motion planning and learning for autonomous vehicles, building on a background in industrial robot design.
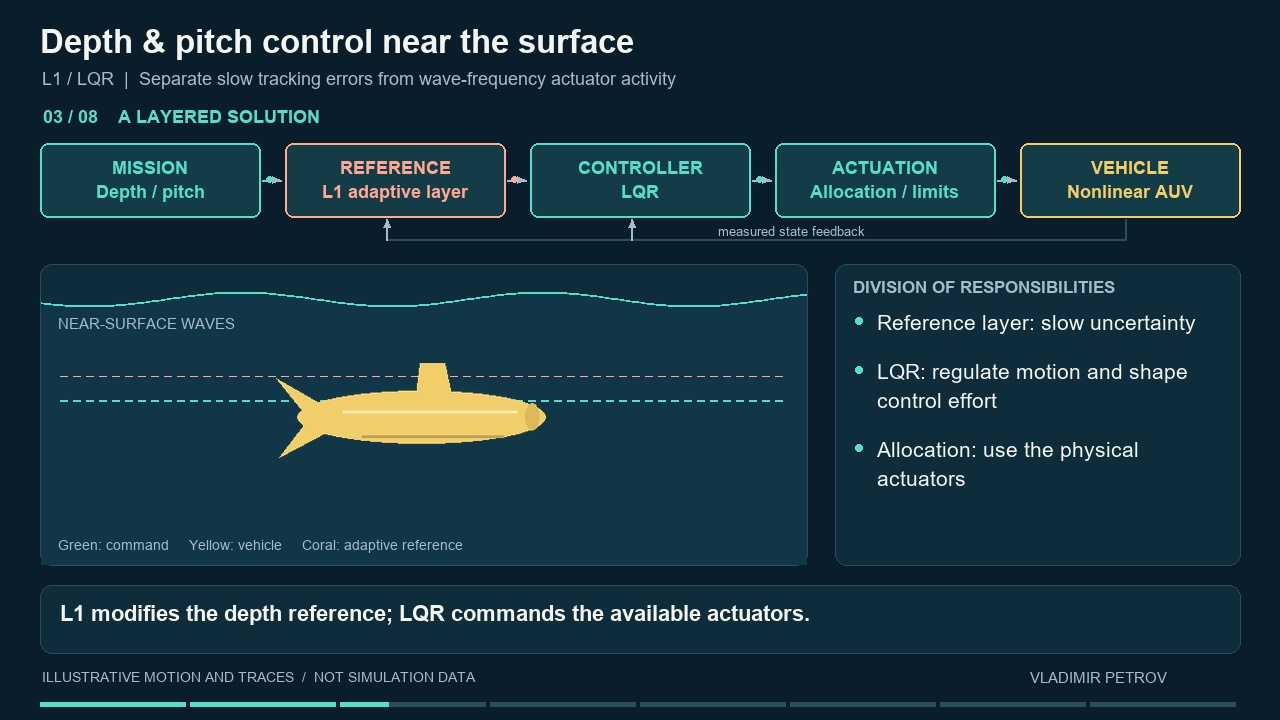
Follow the depth command.
Let the waves pass.
Browse by research setting and career stage.
Published studies, experimental work and a look at the questions I’m exploring next.
10 projects shown
Track a commanded depth while reducing unnecessary actuator activity in waves.
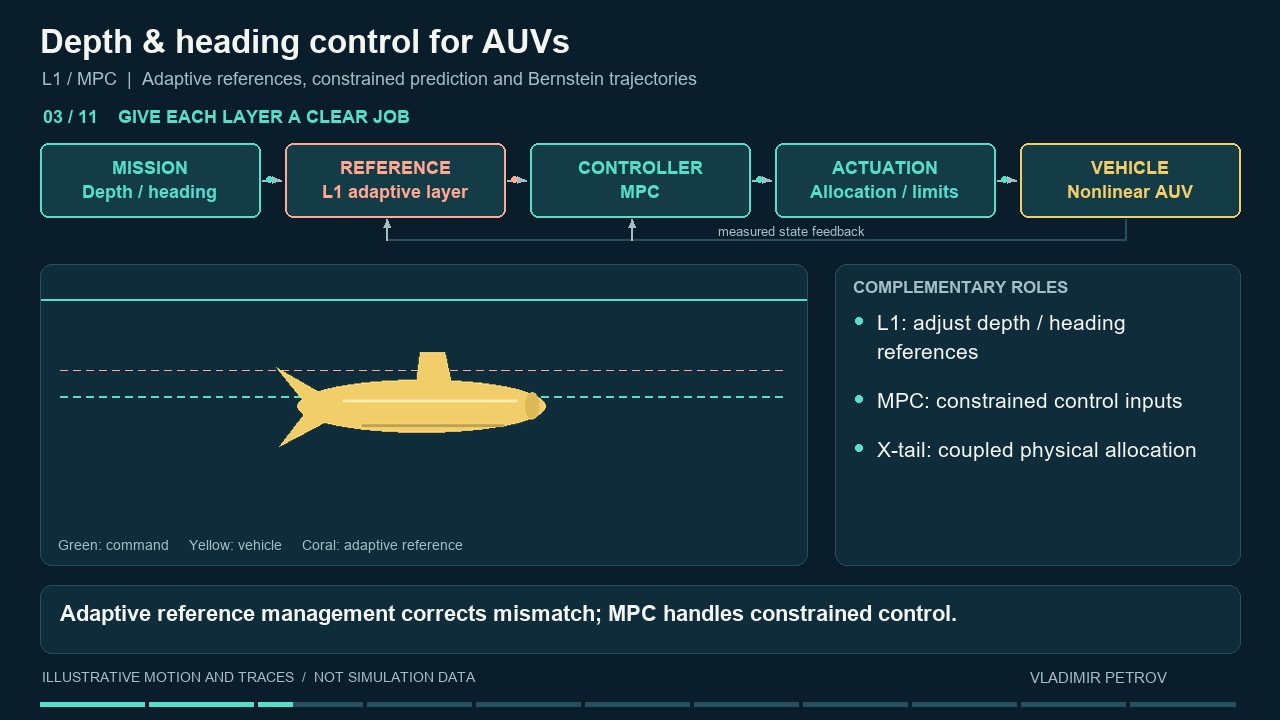
Reach a new depth and heading while working within the vehicle’s actuator limits.
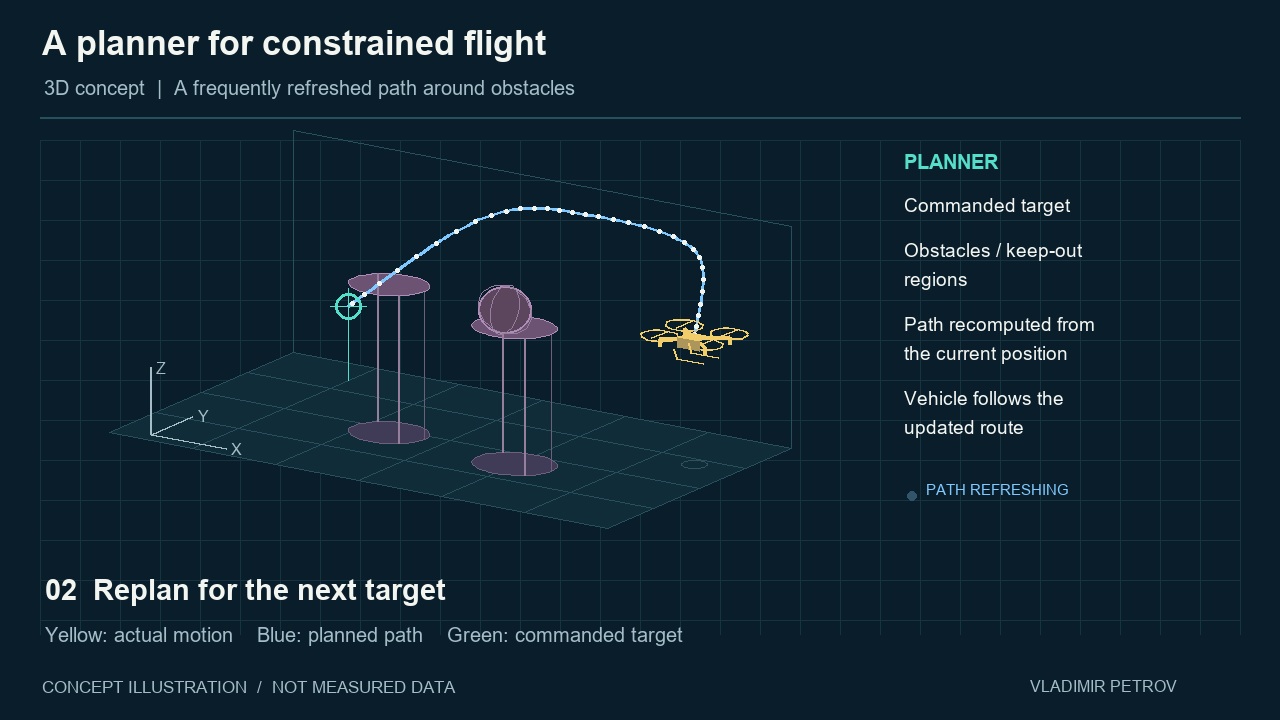
Guide a small drone toward a commanded target through a space with obstacles.
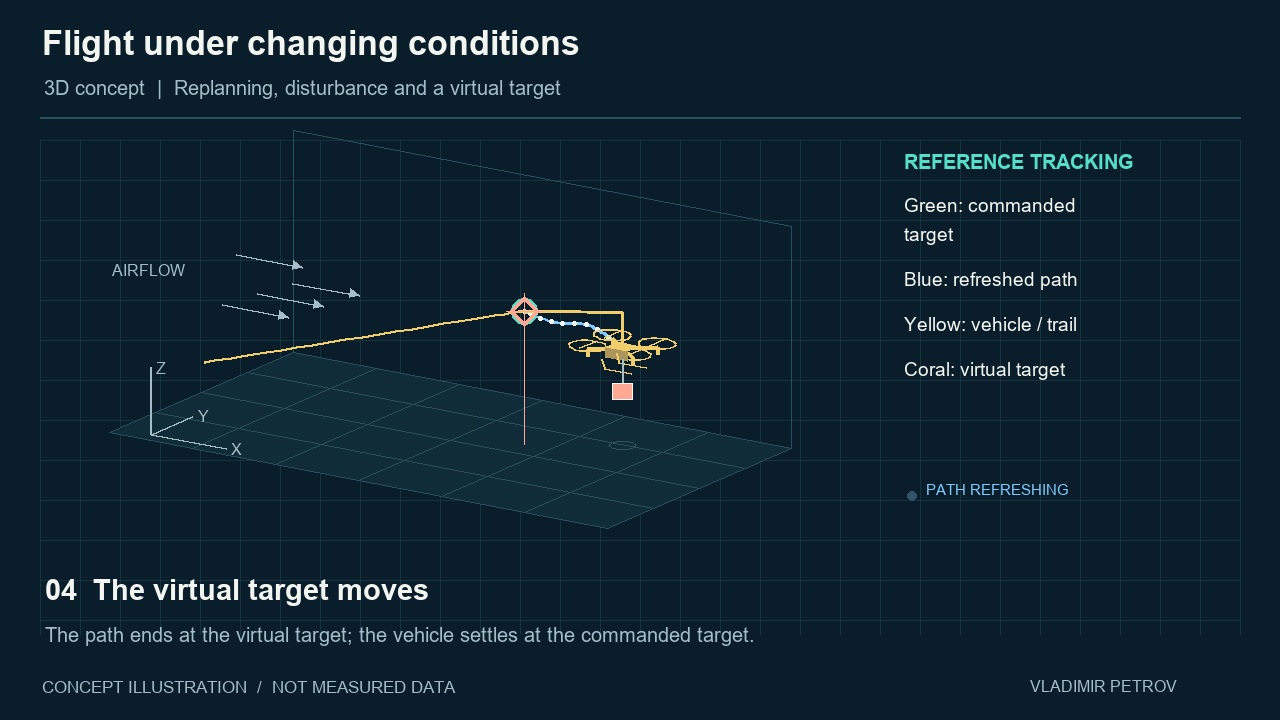
Return to a commanded position despite airflow and changes in carried mass.
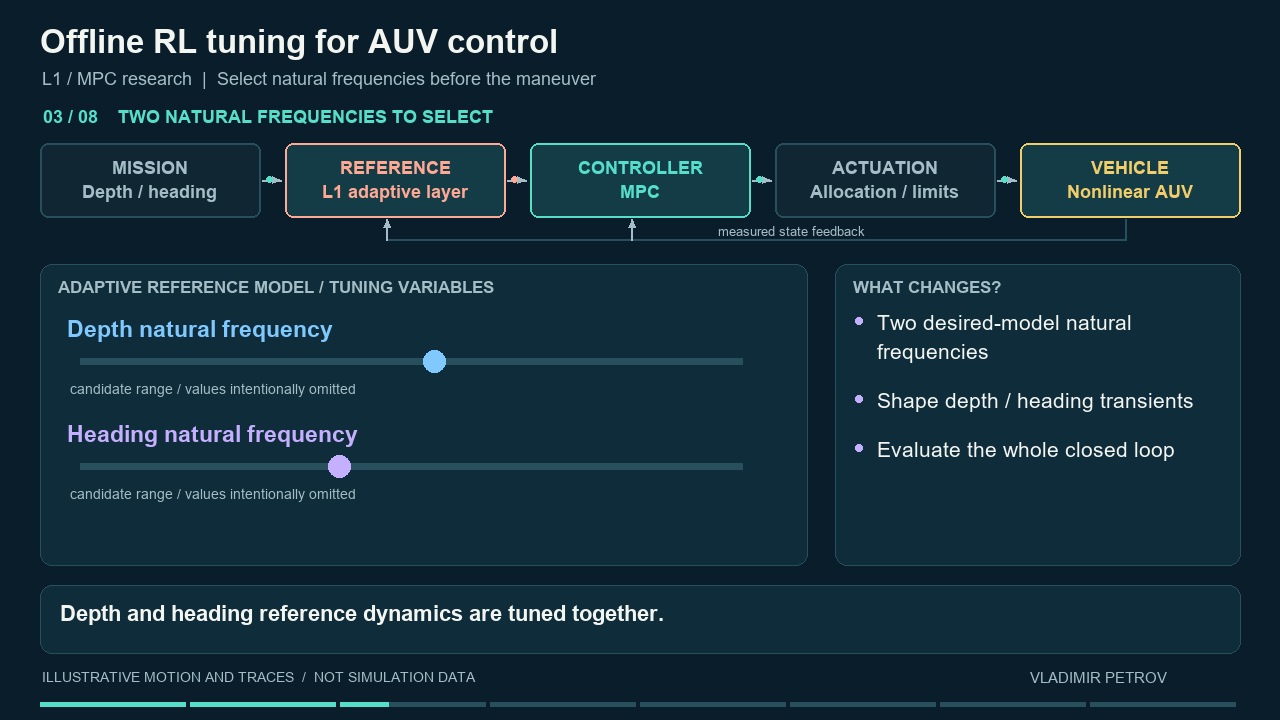
Use offline reinforcement learning to select controller settings for depth and heading maneuvers.
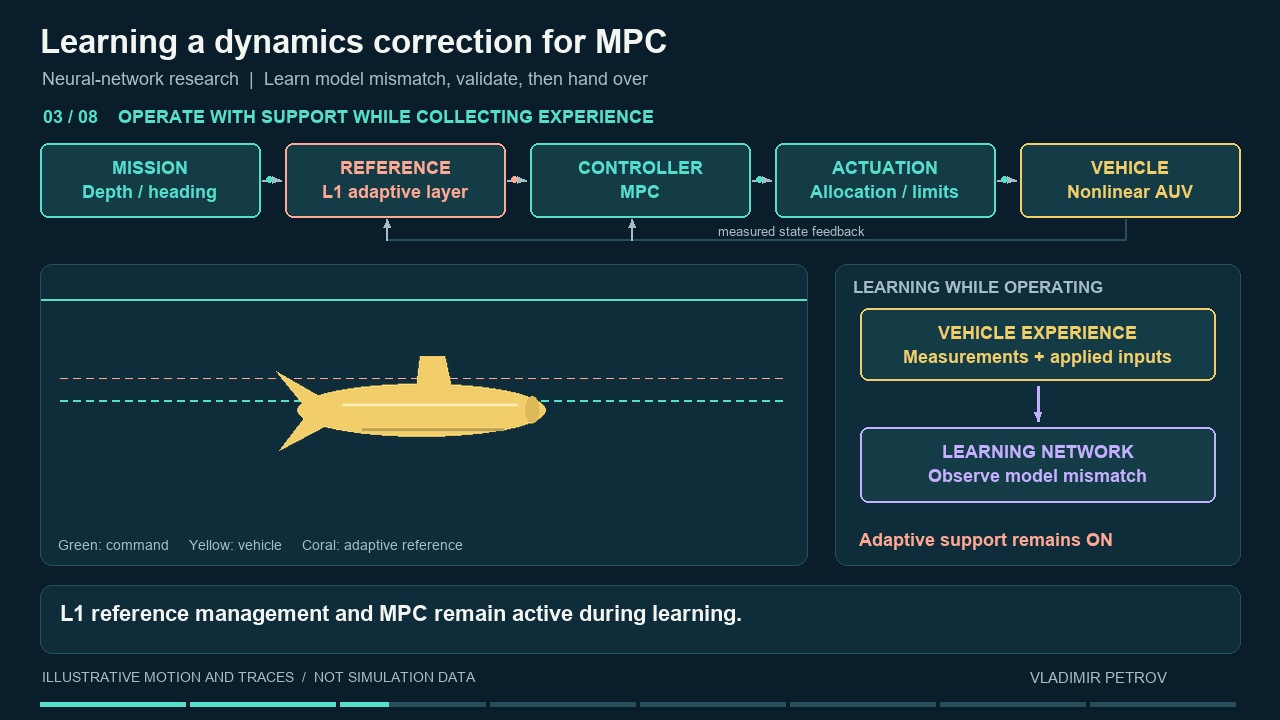
Learn a reusable model correction and investigate a validated handover from adaptive support to learned predictive control.
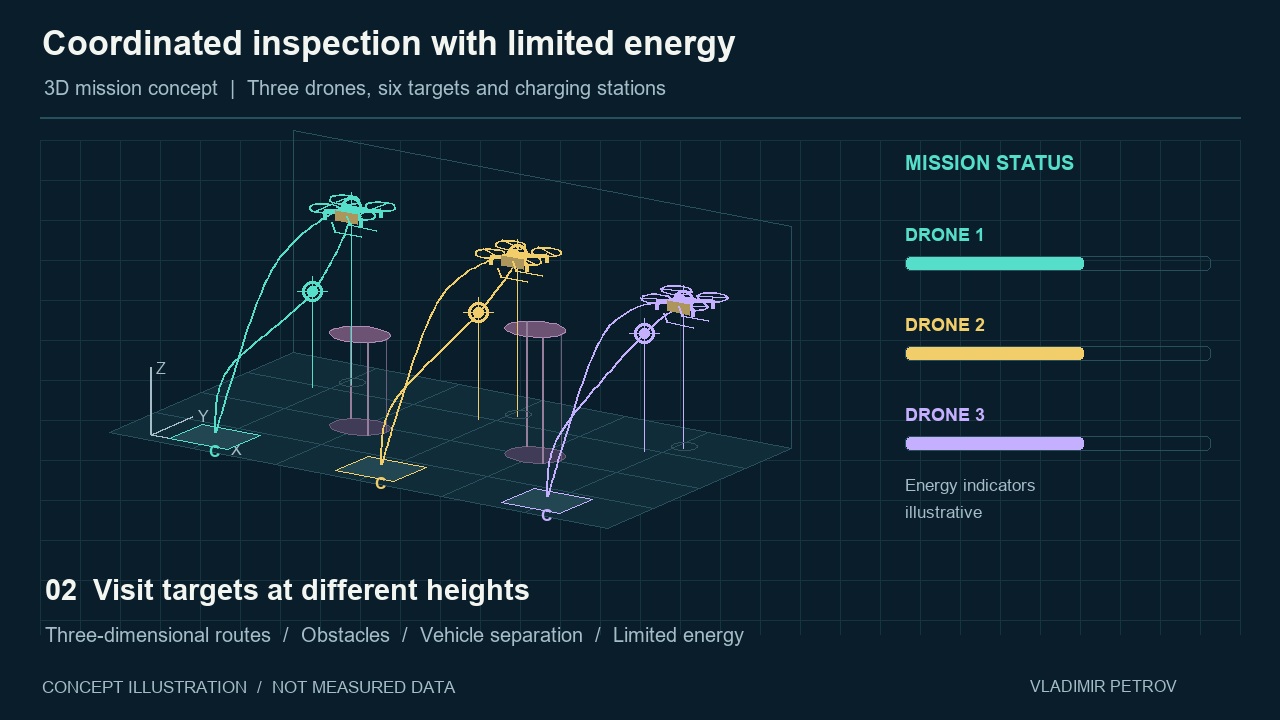
Bring coordinated inspection missions into a real-drone experimental pipeline.
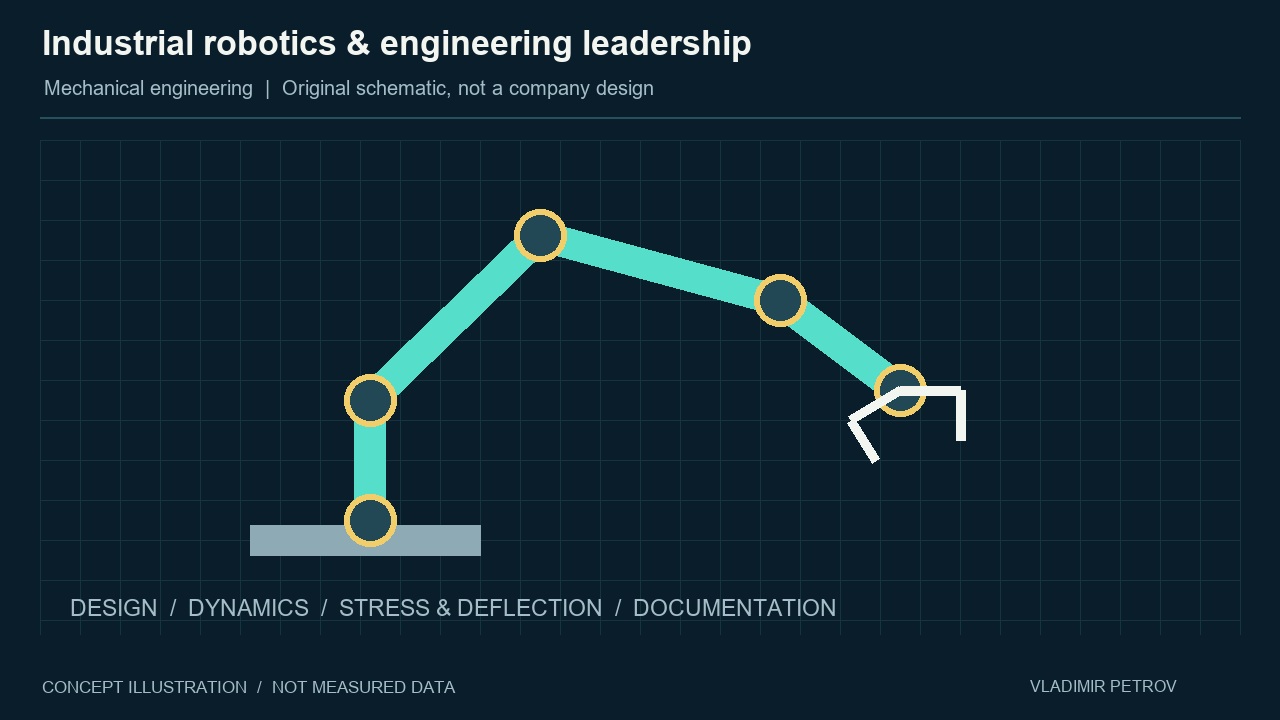
Lead the mechanical development of industrial robotic systems.
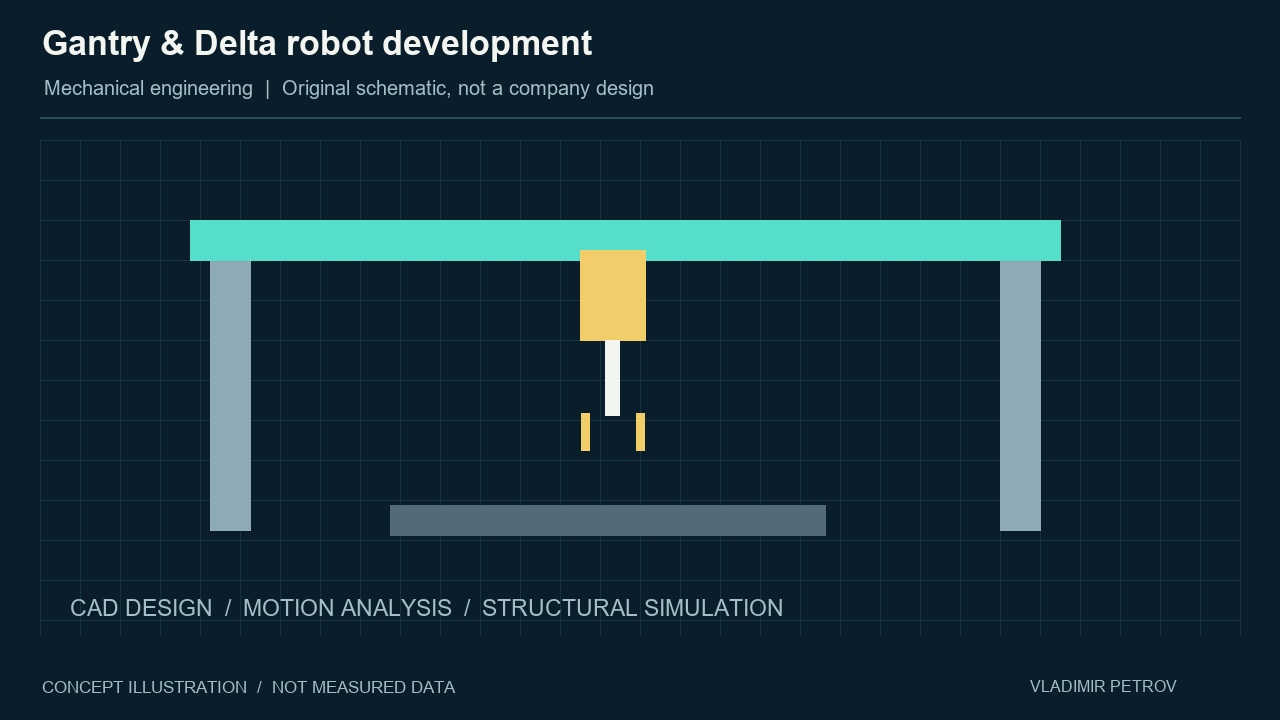
Develop robot mechanisms and evaluate how they move and carry load.
Build a foundation in the mechanical design and analysis of robotic systems.
The path here
Mechanical design of Delta and articulated robotic systems.
Gantry and Delta robot development, CAD and simulation.
Led a 24-person mechanical engineering team.
PhD research in autonomous systems, with a MERL internship in 2025.